
OpenADS is an open-source ecosystem for connected and autonomous driving built on ROS 2. It provides a complete reference software stack for SAE Level 4 automated driving, simulation with CARLA and SUMO, developer tools, and benchmarks for verification and validation – released under the Apache 2.0 license. OpenADS runs on real research vehicles and road infrastructure. It is open to partners from research and industry (see 🤝 Support).
📖 Documentation · 🚀 Quick Start · 🎬 Video · 📋 Backlog · 🤝 Support
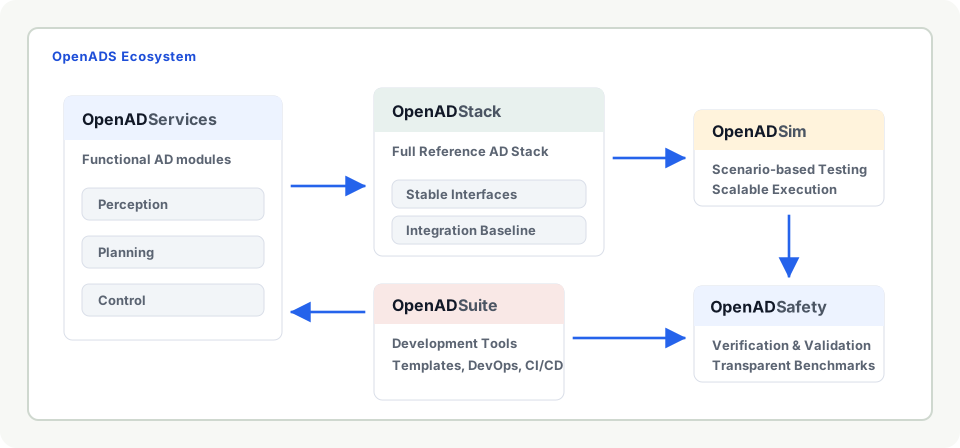
| Component | Description | Release | Documentation |
|---|---|---|---|
| 🤖 OpenADStack | Open-source Level 4 automated driving stack on ROS 2: localization, perception, prediction, planning and control in a Docker Compose based reference stack. |  |
OpenADStack |
| 🧩 OpenADServices | Modular, reusable ROS 2 building blocks that make up the stack and can also be used on their own. | multiple | Functional architecture |
| 🎮 OpenADSim | Closed-loop simulation and scenario-based testing of the stack with CARLA or SUMO. |  |
OpenADSim |
| 🛠️ OpenADSuite | Developer tools: module template, development environment, Helm charts, monitoring and ROS 2 analysis tools. | multiple | OpenADSuite |
| 🛡️ OpenADSafety 🚧 | Tools and transparent benchmarks for verification and validation of automated driving modules and full stacks. | in progress | OpenADSafety |
Try OpenADStack in a few minutes: the demo runs the stack open-loop on recorded ROS 2 data (Docker required).
git clone https://github.com/openads-project/openadstack.git
cd openadstack/demo
xhost +local:
docker compose up -d
For closed-loop simulation with CARLA or SUMO, start with OpenADSim. System requirements and further options are described in the Quick Start guide.
| Domain | Repositories |
|---|---|
| Localization & maps | lanelet2_map_server – ROS 2 HD Map Server for Automated Driving based on Lanelet2 |
| Perception | point_cloud_object_detection – ROS 2 Point Cloud Object Detection for Automated Driving point_cloud_fusion – ROS 2 Point Cloud Fusion of Multiple Point Clouds into a Single Point Cloud pcod-common – Shared Preprocessing and Postprocessing Library for Point Cloud Object Detection triton_cpp – Wrapper for Triton C++ Client Libraries |
| Prediction | lanelet2_object_list_prediction – ROS 2 Object List Prediction for Automated Driving based on Lanelet2 |
| Planning | lanelet2_route_planning – ROS 2 Route Planning for Automated Driving based on Lanelet2 simple_planner – ROS 2 Reference Trajectory Planning for Automated Driving trajectory_optimization – ROS 2 Trajectory Optimization for Automated Driving based on an Optimal Control Problem (OCP) |
| Control | ackermann_trajectory_control – Cascaded ROS 2 PID Controller for Ackermann steered vehicles |
| Simulation & bridges | carla-simulator – High-fidelity rendering and physics backend based on CARLA for closed-loop sensor and vehicle simulation carla-ros-bridge – Bidirectional communication bridge between CARLA simulation and ROS ecosystems carla-scenario-runner – OpenSCENARIO execution for scenario-based testing and evaluation in CARLA carla_converter – Converter for CARLA specific ROS 2 data to OpenADS interfaces simulation_adapter – Adapts OpenADSim data to vehicle-specific OpenADStack interfaces ros_middleware_bridge – ROS 2 middleware bridge serializing topic data between different RMW implementations |
| Developer tools | openads-dev-environment – Common development environment for OpenADS modules openads_demo_service – Template repository for new OpenADServices openads-helm – Essential OpenADS Helm Charts monitoring – Monitoring and visualization using RViz and RQt with support for message definitions used in OpenADS ros2_graph_export – ROS 2 Node and Topic Graph Exporter ros2_unbag_plugins – Plugins for ros2_unbag topic export with the openADS interfaces ros2-trace-analysis – Analyze ROS 2 execution traces to understand system performance and timing behavior openads-assets – Shared 3D meshes and URDF robot descriptions for OpenADS |
 |
 |
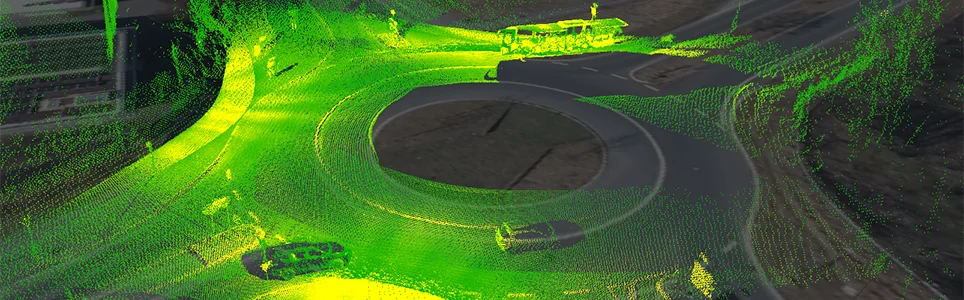 |
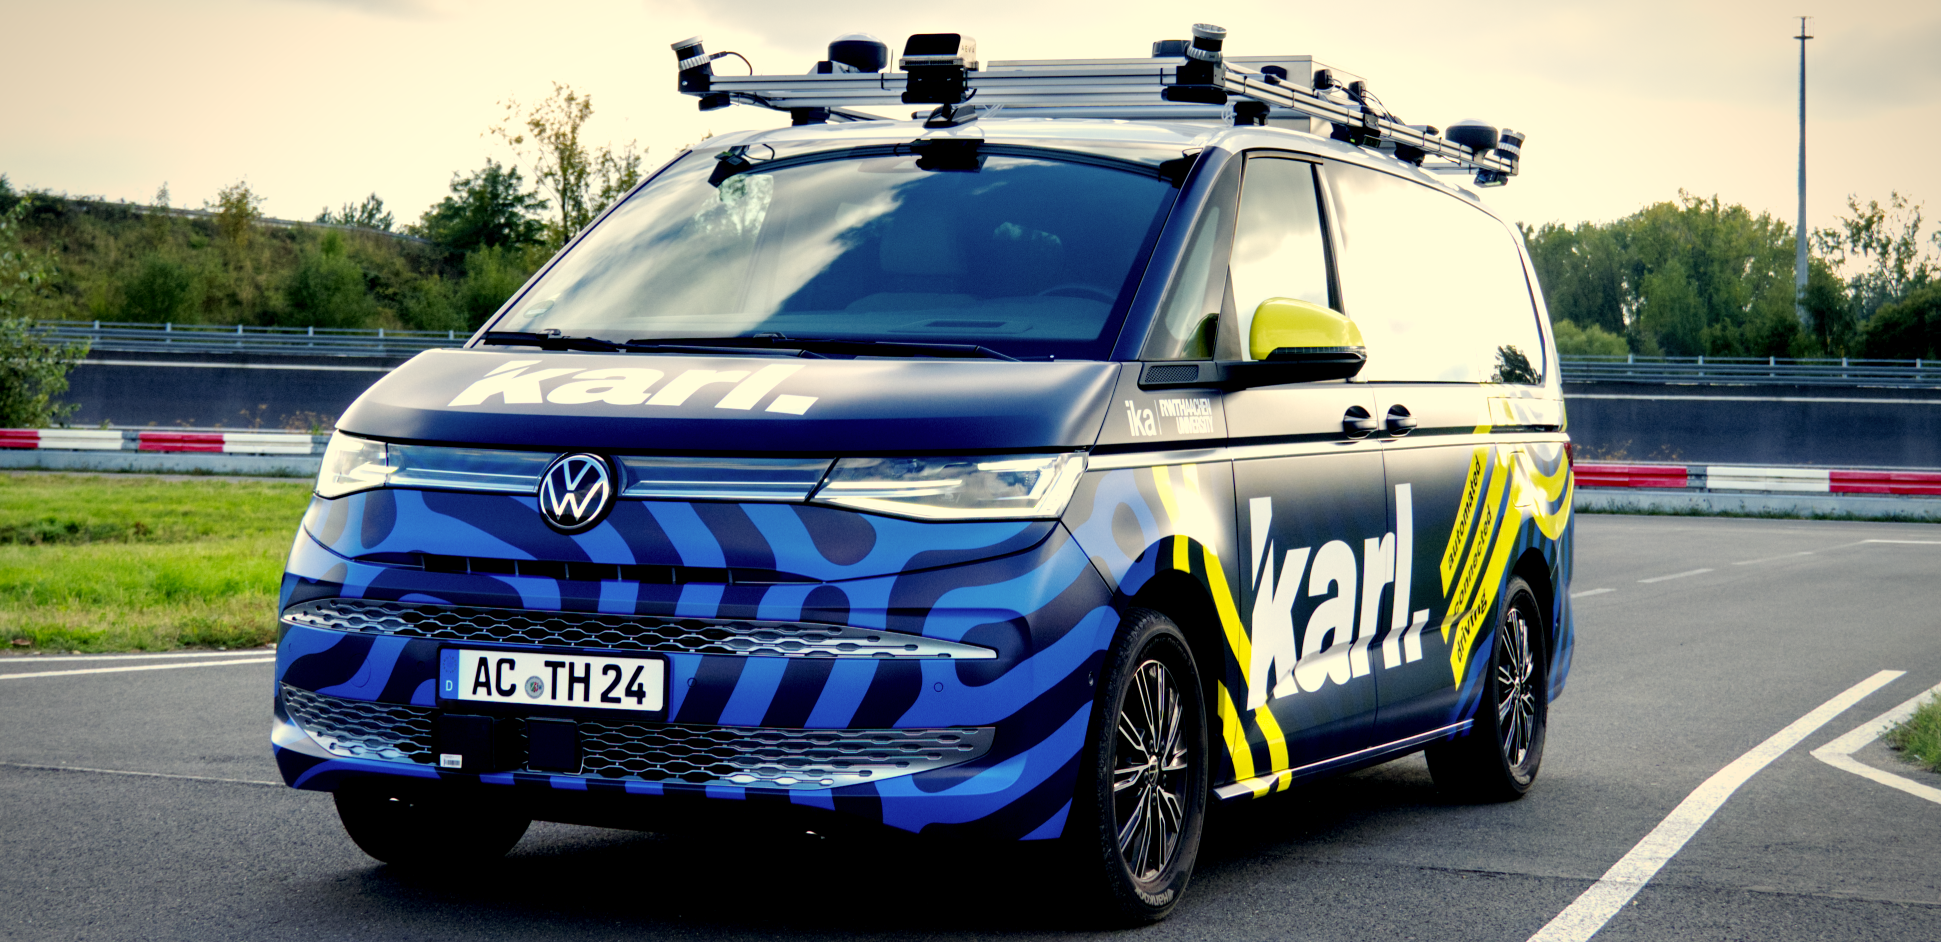
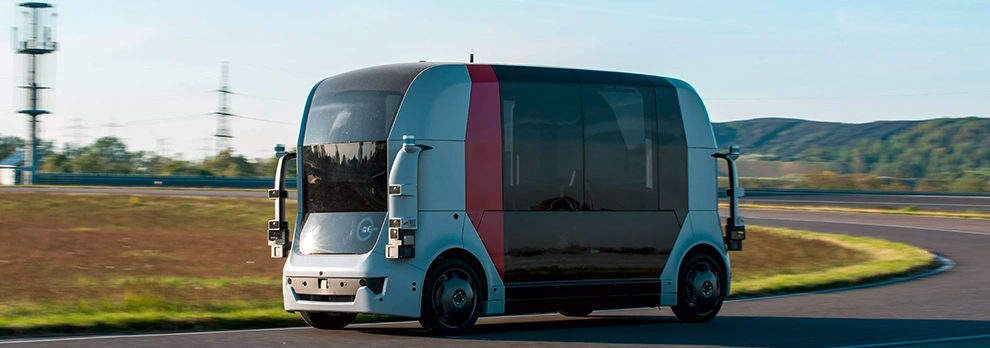
| karl. – ika's research vehicle for automated and connected driving | autoSHUTTLE – driverless shuttle built from scratch in UNICARagil | RITA – roadside infrastructure test field in Aachen |
Using OpenADS in your own vehicle, robot or test field? Add your integration to the documentation.
OpenADStack follows a Doer/Checker/Fallback pattern. The current release combines learned perception with a rule-based planner. Next, a learned planner will act as Doer while the rule-based planner remains the safety Checker, supported by an MLOps process for continual improvement (planned until the end of 2026). After that, an end-to-end driving model is planned as Doer (until the end of 2027). Details are in the OpenADStack README.
OpenADS explores how distributed partners can build compatible automated driving services and use benchmarks to identify stronger system compositions. The work is embedded in Germany's Ecosystem Mobility 4.0 initiative and aligned with the goals of the European Connected and Autonomous Vehicle Alliance (ECAVA).
- See what we are working on in the backlog.
- Ask questions, report bugs or propose features as described on the Support page.
- Start a new module from the OpenADService template.
- Contact: Public Matrix chat or opensource@ika.rwth-aachen.de
| Date | Place | Event |
|---|---|---|
| 15 September 2026 | Naples, Italy | OpenADS Tutorial at the IEEE International Conference on Intelligent Transportation Systems (ITSC) – slides and video available |
OpenADS has been developed and used in national and European research projects, including UNICARagil, autotech.agil, 6GEM and 6GEM+, 4CAD, AIthena, AIggregate, SYNERGIES and iEXODUS.
OpenADS – Open Automated Driving Systems · open-source software for automated driving on ROS 2 · Apache 2.0


