





Building physical robots and autonomous systems where claims are backed by code, measurements, and real hardware.
Focused on SLAM, robotic manipulation, embedded autonomy, and reliable autonomous systems.
Evidence over hype.
Portfolio · Contact · Open Source
ROS 2 / SLAM
Ground truth benchmarking, trajectory evaluation, loop closure analysis, and reproducible evidence.
Robotic Manipulation
Physical control, calibration, gesture teleoperation, endpoint accuracy, and repeatability.
Autonomous Systems
Durable execution, explicit authority, recovery, verification, and local first orchestration.
Open Source
Focused upstream contributions where the work can be reviewed, tested, and accepted.
Three systems, one standard: implementation, measurable evidence, and explicit proof boundaries.
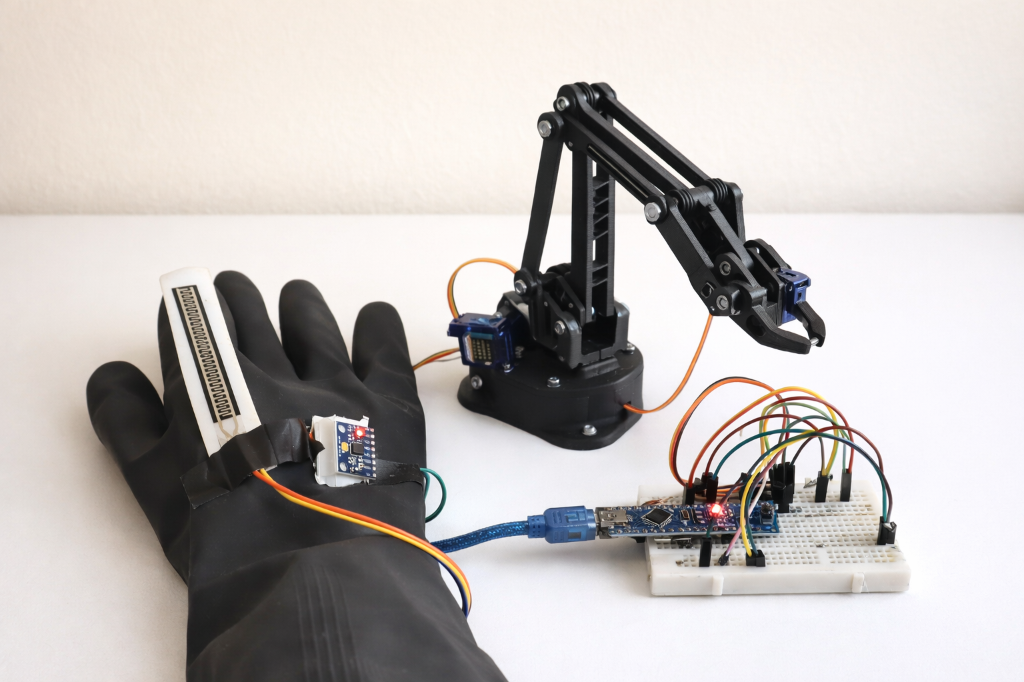
Wearable IMU control over 2.4 GHz RF driving a physical multi joint robotic arm.
C++ · Arduino · MPU6050 · nRF24L01 · PCA9685
Evidence: Physical actuation ✅ · Firmware verification ✅ · Latency and repeatability ✅
Repository → · Actuation video → · Hardware bench → · Verification tests →


A reproducibility first SLAM stack that evaluates estimated motion against independent Gazebo ground truth.
ROS 2 · Gazebo · LiDAR · SLAM Toolbox · ATE · RPE
Evidence: Package and CI contracts ✅ · Verified Gazebo simulation metrics ✅ · Replay and hardware validation ◐ Pending
Repository → · Measured Gazebo evidence → · Benchmark runbook → · Trajectory evaluator → · Release gate →

A local first autonomous execution system that separates model reasoning from persistent authority, state, recovery, and verification.
Python · Model Routing · Durable Missions · Authority Gates · Verification
Evidence: V5.3 verification record ✅ · Cross platform evidence harness ✅ · Windows / WSL2 target proof ◐ Pending
Repository → · Architecture → · Verification record → · Threat model →
A compact view of what is verified now and what is still explicitly gated.
| System | Current proof | Boundary |
|---|---|---|
| Robotic Arm | Physical actuation, hardware bench, firmware tests ✅ | Latency and repeatability still need measurement |
| ROS 2 SLAM | Successful Gazebo benchmark and archived ATE/RPE results ✅ | Rosbag replay, current-main reproduction and hardware pending |
| Universal Brain | V5.3 verification record and cross platform validation harness ✅ | Windows / WSL2 target endurance still pending |
| Open Source | FusionCore #96 and Prefect #23352 merged upstream ✅ | Other PRs remain pending maintainer review |
ROS 2 GNSS frame resolution and TF validation
I fixed a real frame mismatch in FusionCore where GNSS validation could assume gnss_link even when a driver published another frame such as gps.
What changed
- added configurable
gnss.frame_idsupport - resolved the active GNSS frame as configured override → message header →
gnss_linkfallback - used the resolved frame for TF validation and NavSatFix lever arm lookup
- added focused regression coverage for override, message, and fallback precedence
- kept the change scoped to the reported GNSS frame issue
Upstream result: merged September 8, 2026 · 5 files changed · accepted into the original FusionCore repository
View merged PR #96 → · Original issue #81 → · FusionCore repository →
Flow-run activity chart navigation
Fixed the production flow-run activity chart so populated bars provide native, accessible links to the corresponding flow runs. Empty bars remain non-interactive, and regression tests cover click and keyboard navigation without conflicting parent-row behavior.
Upstream result: merged October 9, 2026 (UTC) after maintainer approval and successful UI checks.
View merged PR #23352 → · Prefect repository →
Future contributions appear here only after they are accepted upstream.
| Capability | Evidence based stack |
|---|---|
| Robotics & SLAM | ROS 2 · Gazebo · SLAM Toolbox · LiDAR · TF frames · ATE / RPE · rosbag regression |
| Embedded Control | C++ · Arduino · MPU6050 · nRF24L01 · PCA9685 · servo motion control |
| Autonomous Systems | Python · FastAPI · model routing · durable missions · authority gates · recovery · verification |
| Engineering Infrastructure | Git · CMake · GitHub Actions · automated tests · benchmarking · evidence driven validation |
The emphasis is on technologies used in implemented systems, not an exhaustive list of tools I have touched.
State Estimation & SLAM
Localization, loop closure, trajectory evaluation, and reproducible benchmarking.
Robot Manipulation & Control
Calibration, teleoperation, bounded motion, endpoint accuracy, and repeatability.
Embedded Autonomy
Sensor fusion, RF control, actuator safety, and hardware backed verification.
Reliable Autonomous Systems
Authority, recovery, verification, durable execution, and evidence based completion.
Repositories → · Contribution history → · Merged FusionCore #96 → · Merged Prefect #23352 →
Open to serious work in robotics, autonomous systems, embedded control, and reliable AI systems.
Build · Measure · Verify · Improve